Lupine
Publishers | Surgery & Case Studies: Open Access Journal
Abstract
In this paper, we used the frequency methods for Lyapunov stable
control system to calculate the condition absolute stability
of the control system with electro elastic actuator for nano
bioengineering and microsurgery. We receive the stationary set of the
control system of the hysteresis and butterfly deformation of the
electro elastic actuator in form the segment of the straight line.
Keywords: Condition absolute stability; Control system; Electro elastic actuator; Transfer function; Hysteresis and butterfly
characteristics; Stationary set; Piezoactuator
Introduction
The condition absolute stability on the derivative for the
control system deformation of the electro elastic actuator for
nano bioengineering and microsurgery is determined [1,2]. The
control systems with electro elastic actuator on piezoelectric,
electrostrictive effects solves problems of the matching in the
nano bioengineering and microsurgery, the compensation of the
temperature and gravitational deformations of the equipment, the
correction in the adaptive laser system [1-14]. The electro elastic
actuator for nano bioengineering and microsurgery is used in the
scanning tunneling microscopy and the gene manipulator [15-31].
Condition Absolute Stability of Control System
The electro elastic actuator on piezoelectric, electrostrictive
effects is used in the control systems for the micro and nano
surgical repairs, the micro and nano robotics, the micro and nano
manipulators and injectors for electro elastic [1-6]. The aim of
this work is to calculate the condition of the absolute stability for
control system of the deformation of the electro elastic actuator
for nano bioengineering and microsurgery. The frequency methods
for Lyapunov stable control system are used to determine the
condition of the absolute stability of control system [2] with
electro elastic actuator. We receive the sufficient absolute stability
condition of the Lyapunov stable control system with the hysteresis
nonlinearity of the electro elastic actuator using the Yakubovich
absolute stability criterion with the condition on the derivative.
This criterion is the development of the Popov absolute stability
criterion [2]. The description of the hysteresis nonlinearity of the
electro elastic actuator [16] in the form
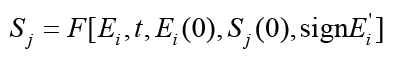
where  is the relative displacement of the cross section of the
electro elastic actuator along
 axis,
 is the control parameter in
the form the electric field strength of the electro elastic actuator
along i axis on the interval [0,t], the initial value of the electric
field strength
 the value of t, the initial value the relative
displacement
 and the sign of the rate
 of the electric field
strength variation. Let us consider hysteresis characteristic of the
deformation of the electro elastic actuator on (Figure 1). The set
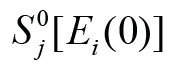 the vertical segment
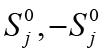 bounded by the points of
intersection of the ordinate axis with the hysteresis loop at the
maximum admissible field strength in the piezoactuator. We receive
for the stable linear part of the control system the stationary set N
and the equation for the straight-line L has the form
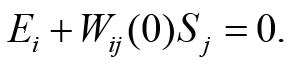
In static regime for the control system for the deformation
of the piezoactuator we receive the value of the transfer function
 of the linear part of the control system. The set of points N for
intersection of this straight line L with the hysteresis characteristic
represents the segment of the straight line marked. At
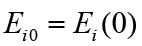 and
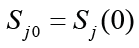 we have the stationary solution to the control system with
hysteresis on Figure 1. We obtain the stationary set in the form of the
marked segment N of straight-line L in Figure 1 with the set
of pairs
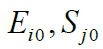 The set of points N for intersection of this straight
line L with the hysteresis characteristic. For the stationary set the
equation has the following form
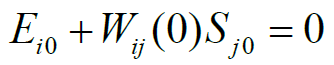
Figure 1: Hysteresis characteristic deformation of piezoactuator.
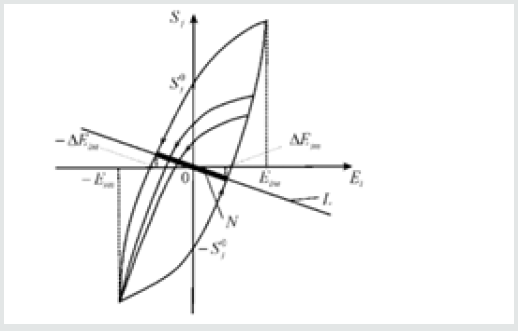
Figure 2: Butterfly characteristic deformation of actuator
with electrostrictive effect.
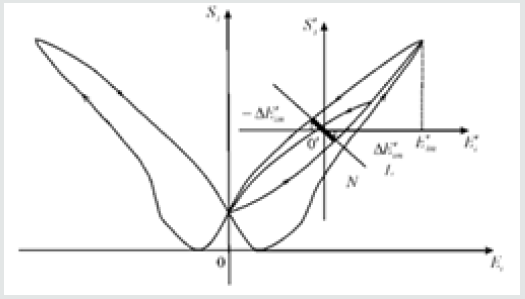
Let us consider butterfly characteristic of the deformation of the
electro elastic actuator for nano bioengineering and microsurgery.
For the actuator with the electrostrictive effect the deformation
characteristic on butterfly wings is observed for unipolar change
of the electric field strength on Figure 2. We have the particular
cycle on one wing of butterfly in the form of the hysteresis loop. For
butterfly type characteristic deformation of actuator in the control
system the coordinate origin is moved to new zero with top dash on
Figure 2. We have stationary set N of the system marked segment
of straight-line L in Figure 2. We receive the continuous function
 the hysteresis loop of the piezoactuator and the quantities of
the derivative
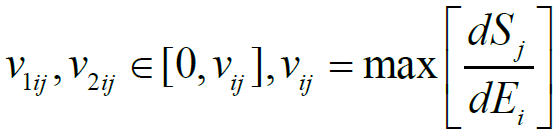
where the quantities of the derivative and are calculated
using the hysteresis characteristic on Figure 1 for the maximum
admissible electric field strength in the piezoactuator. The
quantities and are the minimum and the maximum values of the
tangent of the inclination angle of the tangent line to the hysteresis
nonlinearity of the piezoactuator. Thus, we obtain
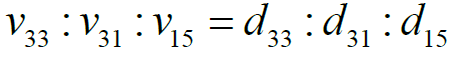
where the ratios of the tangents of the inclination angle of the
tangent line to the hysteresis nonlinearity of the piezoactuator for
longitudinal, transverse and shift piezoeffects are proportional
to the ratios of the piezomodules. We have the expression for
the sufficient condition absolute stability of the system with the
hysteresis nonlinearity of the electro elastic actuator using the
Yakubovich absolute stability criterion with the condition on the
derivative. The Yalubovich criterion is the development of the Popov
absolute stability criterion [2]. The sufficient condition absolute
stability the control system for the deformation of the actuator at
ν1ij=0 and ν2ij=νij have the form
Figure 3: Absolute stability criterion for control system
with electro magneto elastic actuator, shaded corrected
characteristic.
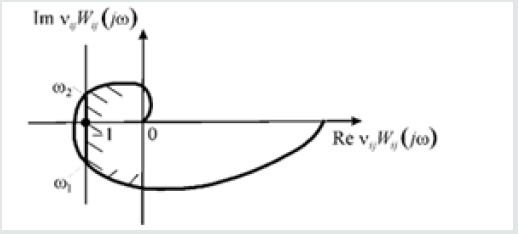
Here 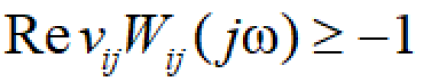 is the amplitude-phase characteristic of the
open-loop system and in brackets j is the imaginary unity and
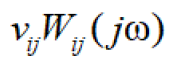 is the frequency The amplitude-phase characteristic of the openloop
system
 on (Figure 3) should be situated to the right
of the straight line
for all values of 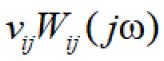
For the piezo actuator from PZT we received the value of the
maximum tangent of the inclination angle of the tangent line to
hysteresis nonlinearity about 1 nm/V for longitudinal piezo effect
and 0.6 nm/V for transverse piezo effect.
Conclusion
For hysteresis and butterfly characteristic in the control system
of the deformation of the electro elastic actuator we obtained the
stationary set in the form the segment of the straight line bounded
by hysteresis loop. The frequency methods are used for calculating
the condition absolute stability of the control system with electro
elastic actuator for nano bioengineering and microsurgery. We
received condition absolute stability on the derivative for the control
system with the electro elastic actuator for nano bioengineering
and microsurgery.
Read More Lupine Publishers Surgery and Case Reports
Journal Articles: https://surgery-casestudies-lupine-publishers.blogspot.com/